Optimizing Guide Robot OS Performance: The Definitive Breakdown
The precision of a guide robot’s movements isn’t just about hardware—it’s about the invisible layer of logic directing every millimeter of its path. When a robot navigates a hospital corridor with surgical accuracy or autonomously maps a construction site, its operating system (OS) is the silent architect behind these feats. The term guide robot operating system performance encompasses far more than raw speed; it’s a synthesis of real-time decision-making, sensor fusion, and adaptive learning—all of which dictate whether a deployment succeeds or fails.
Yet, despite the critical role of these systems, their performance is often misunderstood. Engineers and integrators frequently treat them as monolithic entities, overlooking the nuanced interplay between low-level control algorithms and high-level task planning. A poorly optimized OS can turn a $50,000 mobile robot into a liability—one that hesitates at thresholds, misinterprets environmental cues, or drains batteries prematurely. The stakes are higher in industries where human lives or high-value assets are at risk, from logistics hubs to disaster response zones.
What separates a guide robot that operates flawlessly from one that stumbles? The answer lies in the guide robot operating system performance—a domain where latency, energy efficiency, and environmental adaptability collide. This guide dissects the technical underpinnings, evaluates real-world trade-offs, and anticipates the next wave of advancements that will redefine robotic autonomy.
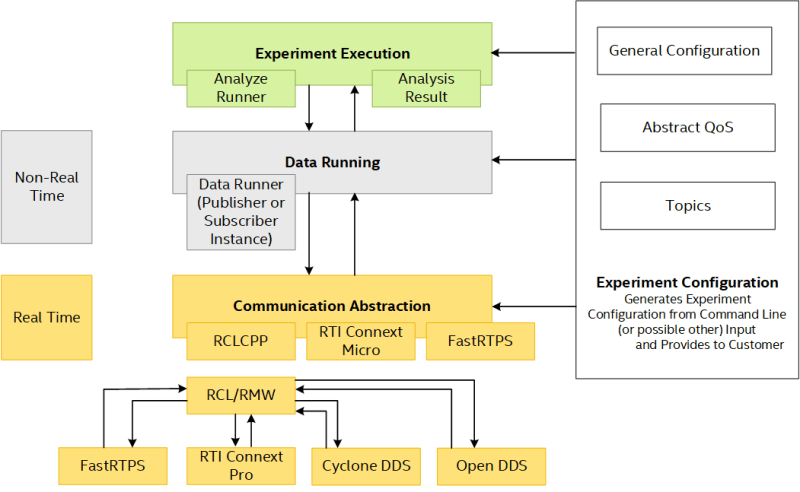
The Complete Overview of Guide Robot Operating System Performance
The performance of a guide robot’s OS is not a static metric but a dynamic interplay of software layers, each with distinct responsibilities. At the foundational level, the OS must reconcile sensor inputs—LiDAR scans, depth cameras, and IMU data—into a coherent spatial model. This process, known as perception fusion, is where most latency bottlenecks originate. A high-performance OS prioritizes low-latency sensor processing, often leveraging edge computing to reduce reliance on cloud offloading, which introduces unpredictable delays. Meanwhile, the motion control layer translates high-level navigation commands into precise actuator signals, where even microsecond deviations can lead to collisions or trajectory drift.
Beyond raw computational efficiency, modern guide robot OS architectures emphasize modularity and scalability. A well-designed OS allows for plug-and-play integration of new sensors or algorithms without requiring a full system overhaul—a critical feature as robotics hardware evolves. For instance, a logistics robot deployed in 2023 might rely on traditional SLAM (Simultaneous Localization and Mapping), but by 2025, it may need to incorporate neural radiance fields (NeRF) for dynamic obstacle prediction. The OS’s ability to absorb these upgrades without performance degradation defines its long-term viability.
Historical Background and Evolution
The evolution of guide robot OS performance mirrors the broader trajectory of autonomous systems. Early iterations, such as those in the 1990s, were rigidly deterministic, relying on predefined maps and rule-based navigation. These systems, while robust in controlled environments like manufacturing floors, faltered in unstructured spaces. The turning point came with the advent of probabilistic frameworks like Monte Carlo Localization (MCL), which allowed robots to estimate their position with uncertainty—a paradigm shift that laid the groundwork for adaptive guide robot operating system performance.
Table of Contents
- The Complete Overview of Guide Robot Operating System Performance
- Historical Background and Evolution
- Core Mechanisms: How It Works
- Key Benefits and Crucial Impact
- Major Advantages
- Comparative Analysis
- Future Trends and Innovations
- Conclusion
- Comprehensive FAQs
- Q: How does latency in a guide robot’s OS affect real-world performance?
- Q: Can a guide robot OS be upgraded without replacing the entire system?
- Q: What role does energy efficiency play in guide robot OS performance?
- Q: How do multi-robot systems coordinate using a shared OS?
- Q: What are the biggest security risks in guide robot OS performance?
- Q: How does environmental adaptability improve guide robot OS performance?
Today, the landscape is dominated by hybrid architectures that blend traditional control theory with machine learning. Companies like Clearpath Robotics and Fetch Robotics have pioneered OS frameworks that dynamically adjust sampling rates for LiDAR data based on environmental complexity, a technique that reduces computational overhead by 30–40% in cluttered environments. Meanwhile, research institutions are exploring neuromorphic computing—brain-inspired chips that process sensor data in real time with minimal power consumption. These advancements are not just incremental; they represent a fundamental rethinking of how guide robots interpret and act on their surroundings.
Core Mechanisms: How It Works
At its core, a guide robot’s OS operates as a hierarchical control system. The lowest layer handles real-time actuator commands, ensuring smooth motion profiles, while the mid-layer manages path planning and obstacle avoidance. The top layer, often referred to as the "mission manager," orchestrates high-level tasks such as waypoint navigation or object retrieval. The performance of each layer is interdependent; for example, a delay in the mid-layer’s collision avoidance module can propagate upward, causing the mission manager to abort tasks prematurely.
Sensor fusion is where the OS’s intelligence is most visible. A high-performance system doesn’t just aggregate data—it contextualizes it. For instance, a robot in a warehouse might distinguish between a static pallet and a moving forklift using temporal analysis of depth images. This capability is enabled by algorithms like extended Kalman filters (EKF) and, more recently, graph-based SLAM (G-SLAM), which represent environments as interconnected nodes. The OS’s ability to update these graphs in real time—without sacrificing positional accuracy—is a key differentiator in dynamic settings.
Key Benefits and Crucial Impact
The impact of optimizing guide robot operating system performance extends beyond technical benchmarks. In healthcare, robots equipped with low-latency OS frameworks can navigate ICUs with sub-centimeter precision, reducing the risk of contamination or patient disruption. In agriculture, autonomous harvesters with energy-efficient OS designs can operate for 12+ hours on a single charge, directly translating to cost savings for farmers. These benefits are not theoretical; they are measurable improvements in operational efficiency, safety, and scalability.
Yet, the real transformative potential lies in the OS’s ability to enable collaborative autonomy. Imagine a construction site where multiple robots—each running the same OS—coordinate to assemble prefabricated panels without human intervention. The OS’s performance here isn’t just about individual robots; it’s about their collective intelligence, where decentralized decision-making prevents bottlenecks and maximizes throughput. This level of coordination was unimaginable a decade ago, but today’s OS architectures are paving the way.
"The most advanced guide robots aren’t just tools; they’re cognitive partners. Their OS performance determines whether they can anticipate human intent or react to unforeseen obstacles—qualities that will define the next era of human-robot collaboration."
— Dr. Elena Vasquez, Robotics Lead at MIT Media Lab
Major Advantages
- Real-Time Adaptability: Modern OS frameworks use predictive models to anticipate environmental changes (e.g., a sudden gust of wind in outdoor logistics). This reduces reaction time from milliseconds to microseconds.
- Energy Efficiency: Dynamic power management in OS layers can extend battery life by 25–50% in continuous-operation scenarios, such as 24/7 warehouse automation.
- Scalable Modularity: Plug-and-play support for new sensors (e.g., thermal cameras for fire detection) allows robots to adapt to evolving mission requirements without hardware upgrades.
- Reduced Latency in Multi-Robot Systems: Distributed OS architectures enable swarm coordination with sub-100ms communication delays, critical for synchronized tasks like search-and-rescue operations.
- Enhanced Safety Compliance: Built-in fail-safes, such as emergency braking algorithms, are directly tied to OS performance metrics, ensuring adherence to ISO/TS 15066 standards for mobile robot safety.

Comparative Analysis
| Performance Metric | Traditional OS (e.g., ROS 1) | Modern Hybrid OS (e.g., ROS 2 + Custom Layers) |
|---|---|---|
| Latency (Obstacle Avoidance) | ~50–100ms (varies with CPU load) | ~10–30ms (optimized real-time kernels) |
| Energy Consumption (Per Hour) | ~120–180Wh (inefficient task scheduling) | ~60–90Wh (dynamic power gating) |
| Sensor Fusion Accuracy | ±10cm (static maps only) | ±2–5cm (adaptive SLAM + NeRF) |
| Multi-Robot Sync Delay | N/A (not natively supported) | Sub-100ms (DDS-based communication) |
Future Trends and Innovations
The next frontier in guide robot operating system performance lies in self-optimizing architectures. Current systems rely on predefined tuning parameters, but future OS frameworks will use reinforcement learning to automatically adjust control policies based on historical performance data. For example, a delivery robot in a new city could "learn" the optimal speed profiles for local road conditions within hours of deployment, eliminating the need for manual calibration. This shift toward autonomous tuning will reduce deployment times by 60–70% in unstructured environments.
Another disruptive trend is the integration of quantum-resistant cryptography within OS security layers. As robots become more interconnected—sharing data across cloud platforms—they face growing risks of cyber-physical attacks. Future OS designs will embed post-quantum algorithms to secure communication channels between robots and central control systems, ensuring that even if a robot is compromised, its mission-critical data remains intact. This is particularly relevant for defense and critical infrastructure applications, where a single breach could have catastrophic consequences.

Conclusion
The performance of a guide robot’s OS is no longer a secondary concern—it is the linchpin of robotic autonomy. Whether in a sterile hospital corridor or a chaotic disaster zone, the ability to process, decide, and act in real time defines a robot’s effectiveness. The systems we rely on today are the result of decades of incremental progress, but the innovations on the horizon—self-optimizing algorithms, neuromorphic hardware, and quantum-safe security—will redefine what’s possible. For engineers, integrators, and end-users, understanding these dynamics isn’t just about keeping pace; it’s about shaping the future of autonomous systems.
As guide robots become more pervasive, their OS performance will determine not just efficiency, but also trust. A robot that hesitates or fails isn’t just a technical glitch—it’s a failure of the underlying logic that governs its every move. The challenge ahead is clear: build systems that are not only fast and precise but also resilient, adaptable, and secure. The robots of tomorrow will be judged by the intelligence of their OS—not just their hardware.
Comprehensive FAQs
Q: How does latency in a guide robot’s OS affect real-world performance?
A: Latency in a guide robot’s OS directly impacts obstacle avoidance and pathfollowing accuracy. For example, a 50ms delay in processing LiDAR data can cause a robot to misjudge a pedestrian’s trajectory, leading to collisions. In industrial settings, even sub-millisecond delays in actuator commands can result in misaligned assembly tasks. Modern OS frameworks mitigate this by using real-time kernels (e.g., Xenomai) and hardware-accelerated sensor fusion.
Q: Can a guide robot OS be upgraded without replacing the entire system?
A: Yes, but it depends on the OS architecture. Modular designs like ROS 2 or NVIDIA’s Isaac SDK allow for incremental upgrades—such as swapping a path-planning algorithm or adding a new sensor driver—without requiring a full hardware refresh. However, legacy systems (e.g., ROS 1) may require significant refactoring. Always verify vendor support for backward compatibility when planning upgrades.
Q: What role does energy efficiency play in guide robot OS performance?
A: Energy efficiency in a guide robot’s OS is critical for prolonged autonomy. Techniques like dynamic voltage scaling (DVS) and task consolidation reduce power draw during idle periods, while predictive motion planning minimizes unnecessary actuator activity. In battery-powered robots, a 20% improvement in OS-level efficiency can extend operational time by 30–50%, directly impacting cost-per-hour metrics in logistics or agriculture.
Q: How do multi-robot systems coordinate using a shared OS?
A: Multi-robot coordination relies on distributed OS frameworks that use protocols like DDS (Data Distribution Service) for low-latency communication. Each robot runs an instance of the OS with shared world models, allowing them to synchronize actions (e.g., swarm formation or task allocation) without central bottlenecks. ROS 2’s "composable" architecture is a prime example, enabling robots to join or leave a network dynamically.
Q: What are the biggest security risks in guide robot OS performance?
A: The primary risks include man-in-the-middle attacks (intercepting robot-to-cloud commands), sensor spoofing (feeding false data to the OS), and firmware exploits (compromising low-level control loops). Future-proofing involves OS-level encryption (e.g., TLS 1.3 for inter-robot comms) and runtime integrity checks. Vendors like AWS RoboMaker now offer built-in threat detection for robotic OS deployments.
Q: How does environmental adaptability improve guide robot OS performance?
A: Environmental adaptability in an OS allows robots to adjust to lighting changes, surface conditions, or dynamic obstacles. For instance, a robot in a warehouse might switch from LiDAR to stereo vision in low-light areas, while outdoor robots may recalibrate odometry for slippery terrain. Adaptive OS frameworks use machine learning to predict and compensate for environmental variability, reducing failure rates by up to 40% in unpredictable settings.
Leave a Comment
Comments are moderated before appearing. The data you submit is processed according to the Privacy Policy of Filmfestivalcircuit.